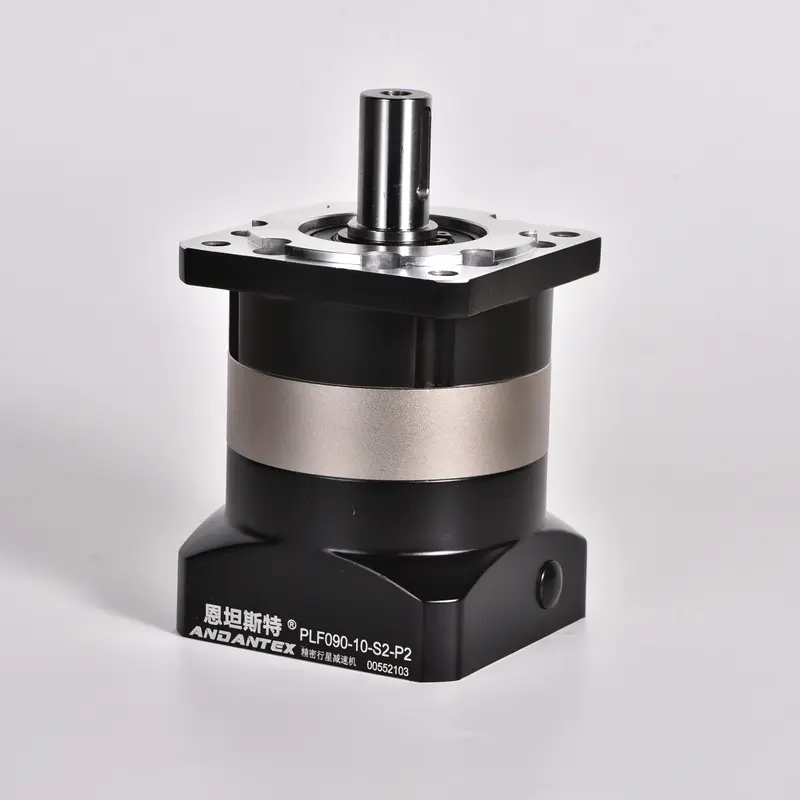
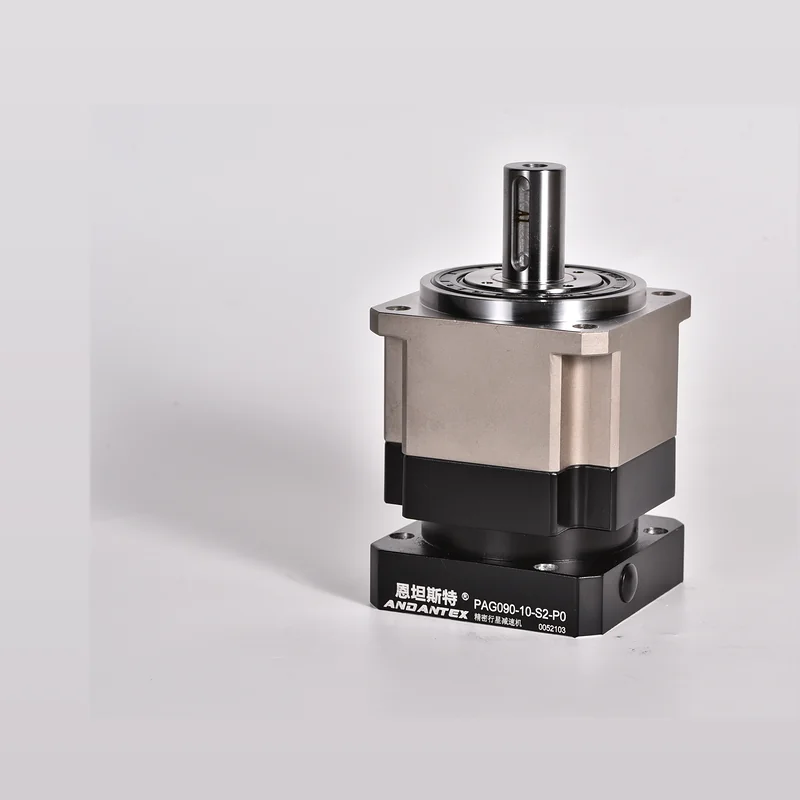
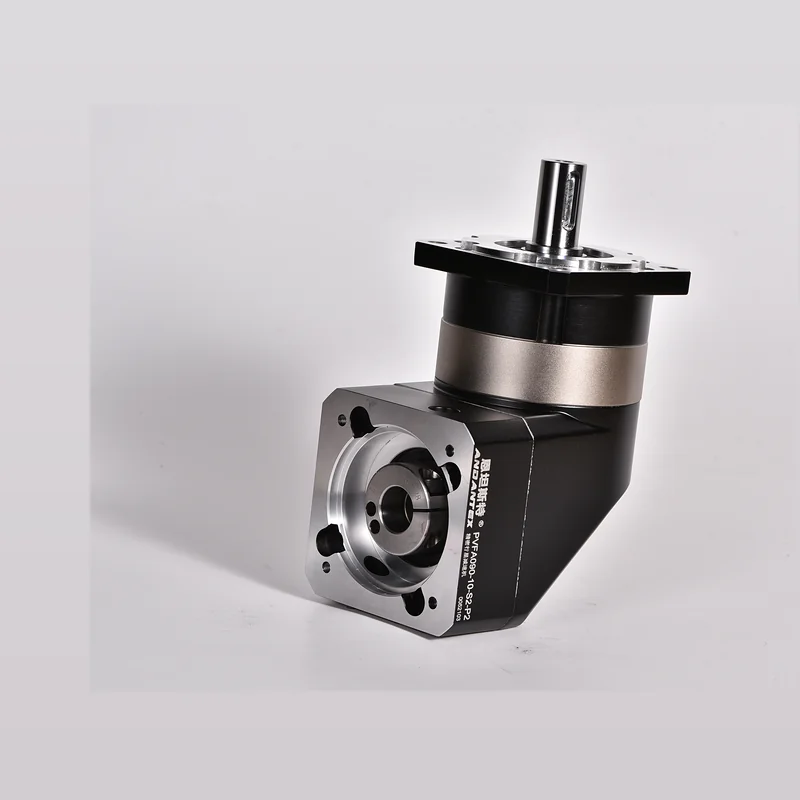
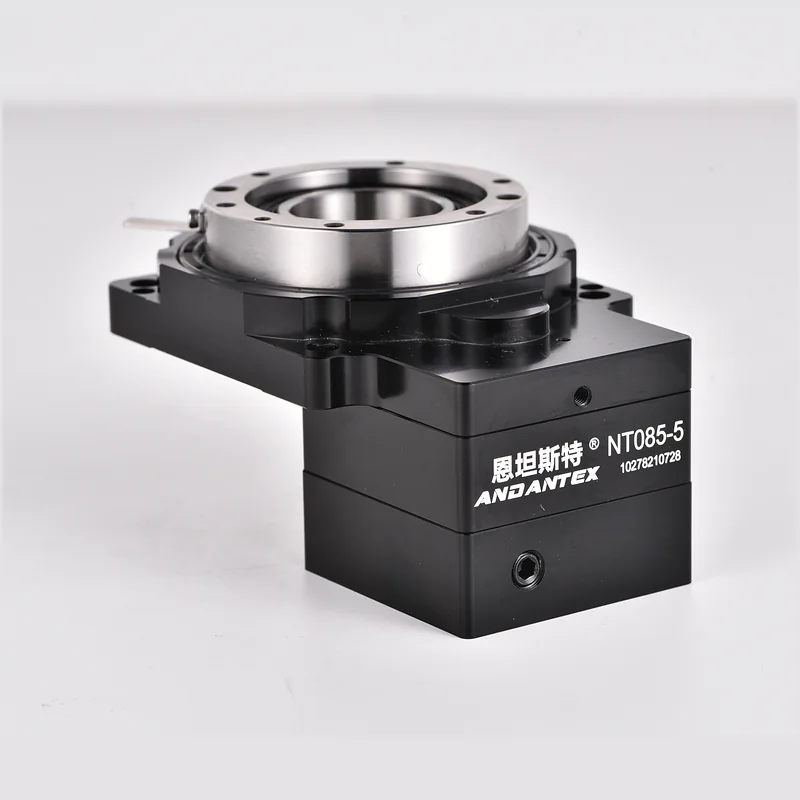
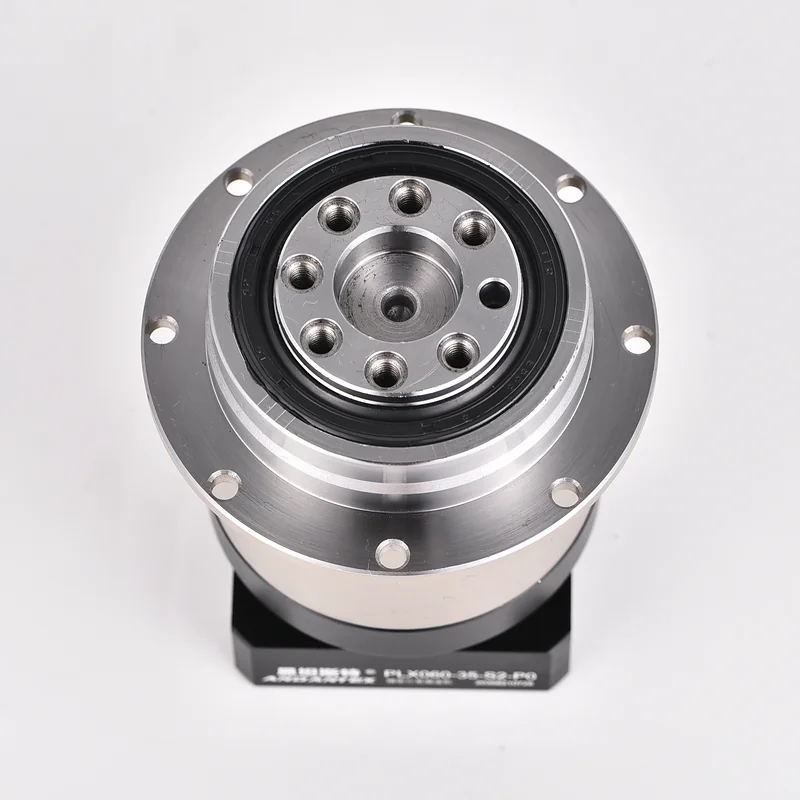
90 Frame Helical Disc-Flange Output, High Rigidity, Low Backlash, Suitable for High-Precision Automation.

90 Frame Helical Disc-Flange Output, High Rigidity, Low Backlash, Suitable for High-Precision Automation.
The following specifications are compiled from published website data, Final model-by-model verification by an engineer is recommended.
| Item | Parameters | Description |
|---|---|---|
| Example Model | PLX090-5-S2-P0 | Helical Disc-Flange Output |
| Gear Ratio | 5 | Published Example |
| Rated Output Torque | 125 Nm | Published Example Value |
| Backlash | 3 arcmin | Published Example Value |
| Maximum Radial Force | 4100 N | Official Website Data |
| Maximum Axial Force | 1025 N | Official Website Data |
| Torsional Rigidity | 31 Nm/arcmin | Official Website Data |
| Maximum Input Speed | 6000 rpm | Official Website Data |
Calculate the gear ratio from the output speed first, Then check rated torque, Peak Torque, Inertia & Cycle Time.
Currently Listed 2 Interface Groups, Including 2 Groups with Verified Examples. Final orders must be verified against the motor drawing.
| Interface Code | Shaft Diameter | Locating Pilot | Mounting Hole Spacing | Typical Motor | Description | Status |
|---|---|---|---|---|---|---|
| 19-70-90 L1 |
19 mm | 70 mm | 90 mm | 750W Common Servo Interfaces | Common High-Precision Disc-Flange Interfaces | Verified Example |
| 19-95-130 L2 |
19 mm | 95 mm | 130 mm | Replacement Applications / Large Pilot Diameter | Neugart Replacement Interface Example | Verified Example |
2D, 3D Motor interfaces are managed under the same product model, Different motor interfaces do not require duplicate product pages.
Input interfaces and dynamic operating conditions are easily overlooked. In addition to gear ratio and rated torque, Check motor shaft dimensions as well, Pilot Diameter, Hole Spacing, Acceleration & Deceleration Time, Inertia & Offset Loads.
Confirm the shaft diameter against the motor drawing, Shaft Length, Pilot Diameter, Key dimensions including mounting hole spacing, Then determine the input flange and bushing configuration.
Combine the motor interface, Gear Ratio, Output torque and operating conditions in one specification sheet, Reduce repeated clarification.