 PRECISION DRIVE
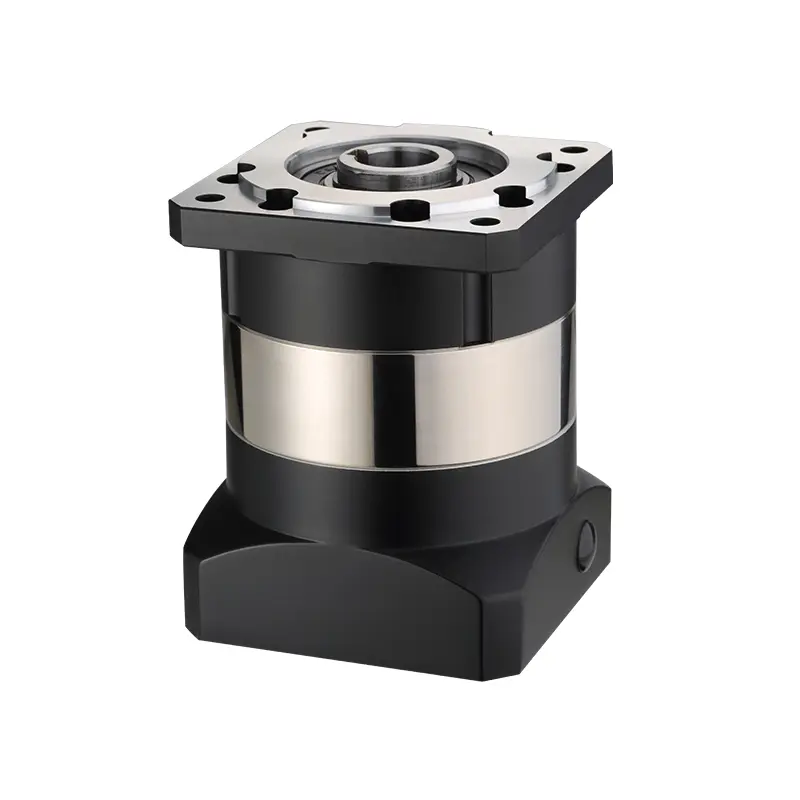
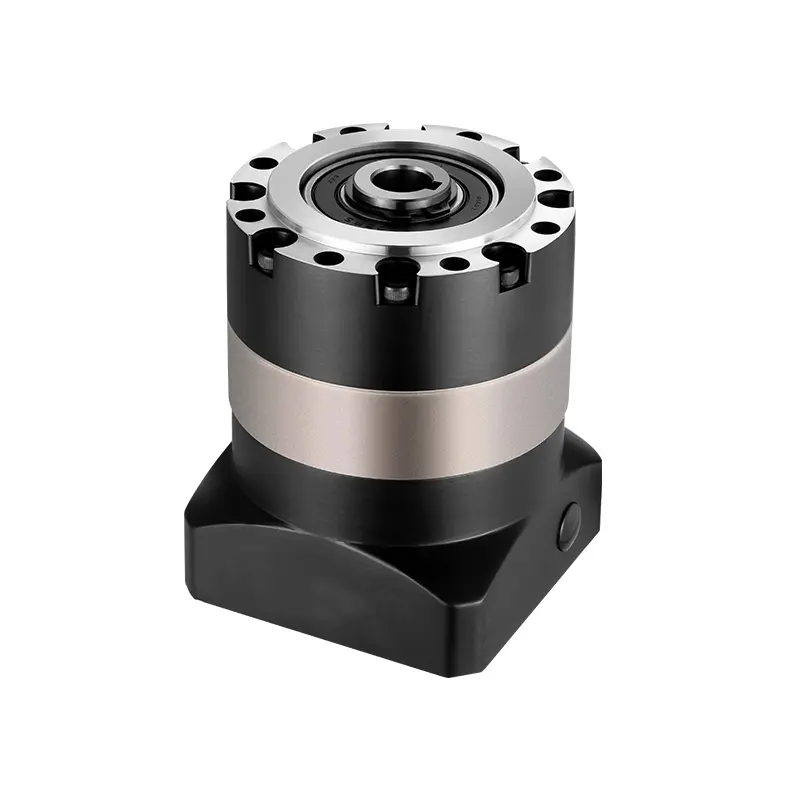
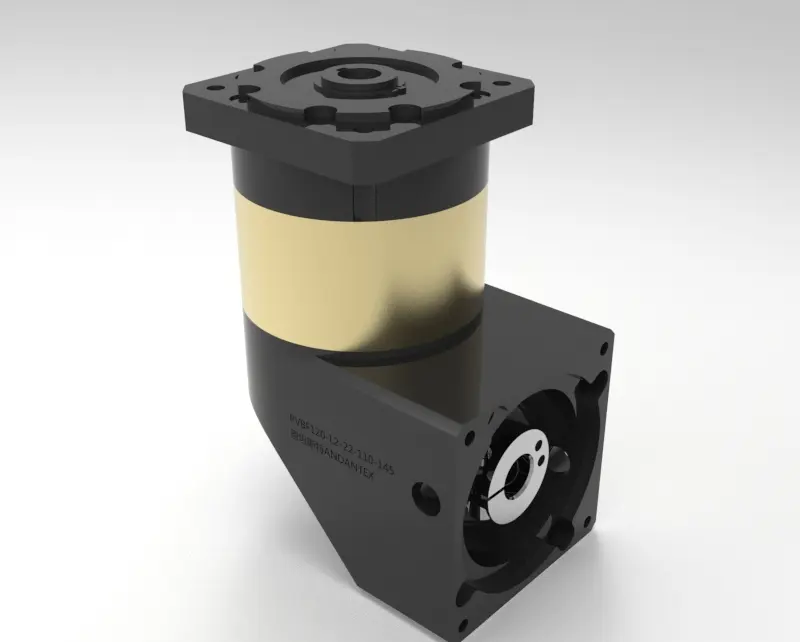
Industrial Robot Joint Drives
Compact joint transmission for precise robotic motion. Consider the ANDANTEX CS25 harmonic reducer for collaborative robots, SCARA rotary axes and suitable joints in six-axis robots, with final selection based on the load and duty cycle.
Application Description
Harmonic reducers for compact robot joints
Industrial robot joints need controlled motion in a limited installation space. Harmonic, or strain-wave, reducers combine a compact transmission layout with low-backlash motion, making them a useful option when positioning performance, size and moving mass matter.
Recommended model: ANDANTEX CS25 Harmonic Reducer
ANDANTEX recommends evaluating the CS25 for suitable robot joint applications. Match the exact configuration to joint torque, speed, reduction ratio, stiffness and the motor interface. The selected reducer must support the full operating cycle, including acceleration and peak loads.
Typical application scenarios
- Collaborative robots: compact joint assemblies where installation space and moving mass are important design constraints.
- SCARA robots: rotary axes for repeatable assembly and pick-and-place motion, subject to cycle-time and load checks.
- Six-axis articulated robots: suitable joints requiring compact reduction and controlled positioning. Each joint must be sized separately for its load and moment.
What determines positioning performance?
Gear backlash is only one part of joint performance. Torsional deflection, lost motion, bearing stiffness, encoder feedback and control tuning also affect the result. Confirm the CS25 specifications for the selected configuration rather than treating zero backlash as a guarantee of zero positioning error.
Request application matching
Send the robot type, joint location, payload, load offset, motion cycle, target speed and motor drawing. Our team can review the CS25 configuration and mounting requirements for your application.
What Matters Most When Selecting for This Application?
- Calculate continuous, acceleration and emergency-stop torque for the specific joint.
- Match the reduction ratio to the required joint speed and motor operating range.
- Check torsional stiffness, lost motion and positioning accuracy under load.
- Verify output bearing capacity, external moments and the mounting interface.
- Confirm lubrication, duty cycle, operating temperature and service-life requirements.
Location & Contact
Dongguan Hanrui Automation Technology Co., Ltd.
6th Floor, No. 172 Chonghuan Middle Road, Shijie Town, Dongguan, China
Phone: +86 769 8281 3091
Email: oliver@andantexcn.com