Skip to content
ANDANTEX / PRECISION TRANSMISSIONSelection Support / 3D Resources / Custom Engineering
Home / Applications / Industrial Robot Joint Drives
ROBOTICS

CS25 Harmonic Reducers for Industrial Robot Joints | ANDANTEX

Compact joint transmission for precise robotic motion. Consider the ANDANTEX CS25 harmonic reducer for collaborative robots, SCARA rotary axes and suitable joints in six-axis robots, with final selection based on the load and duty cycle.

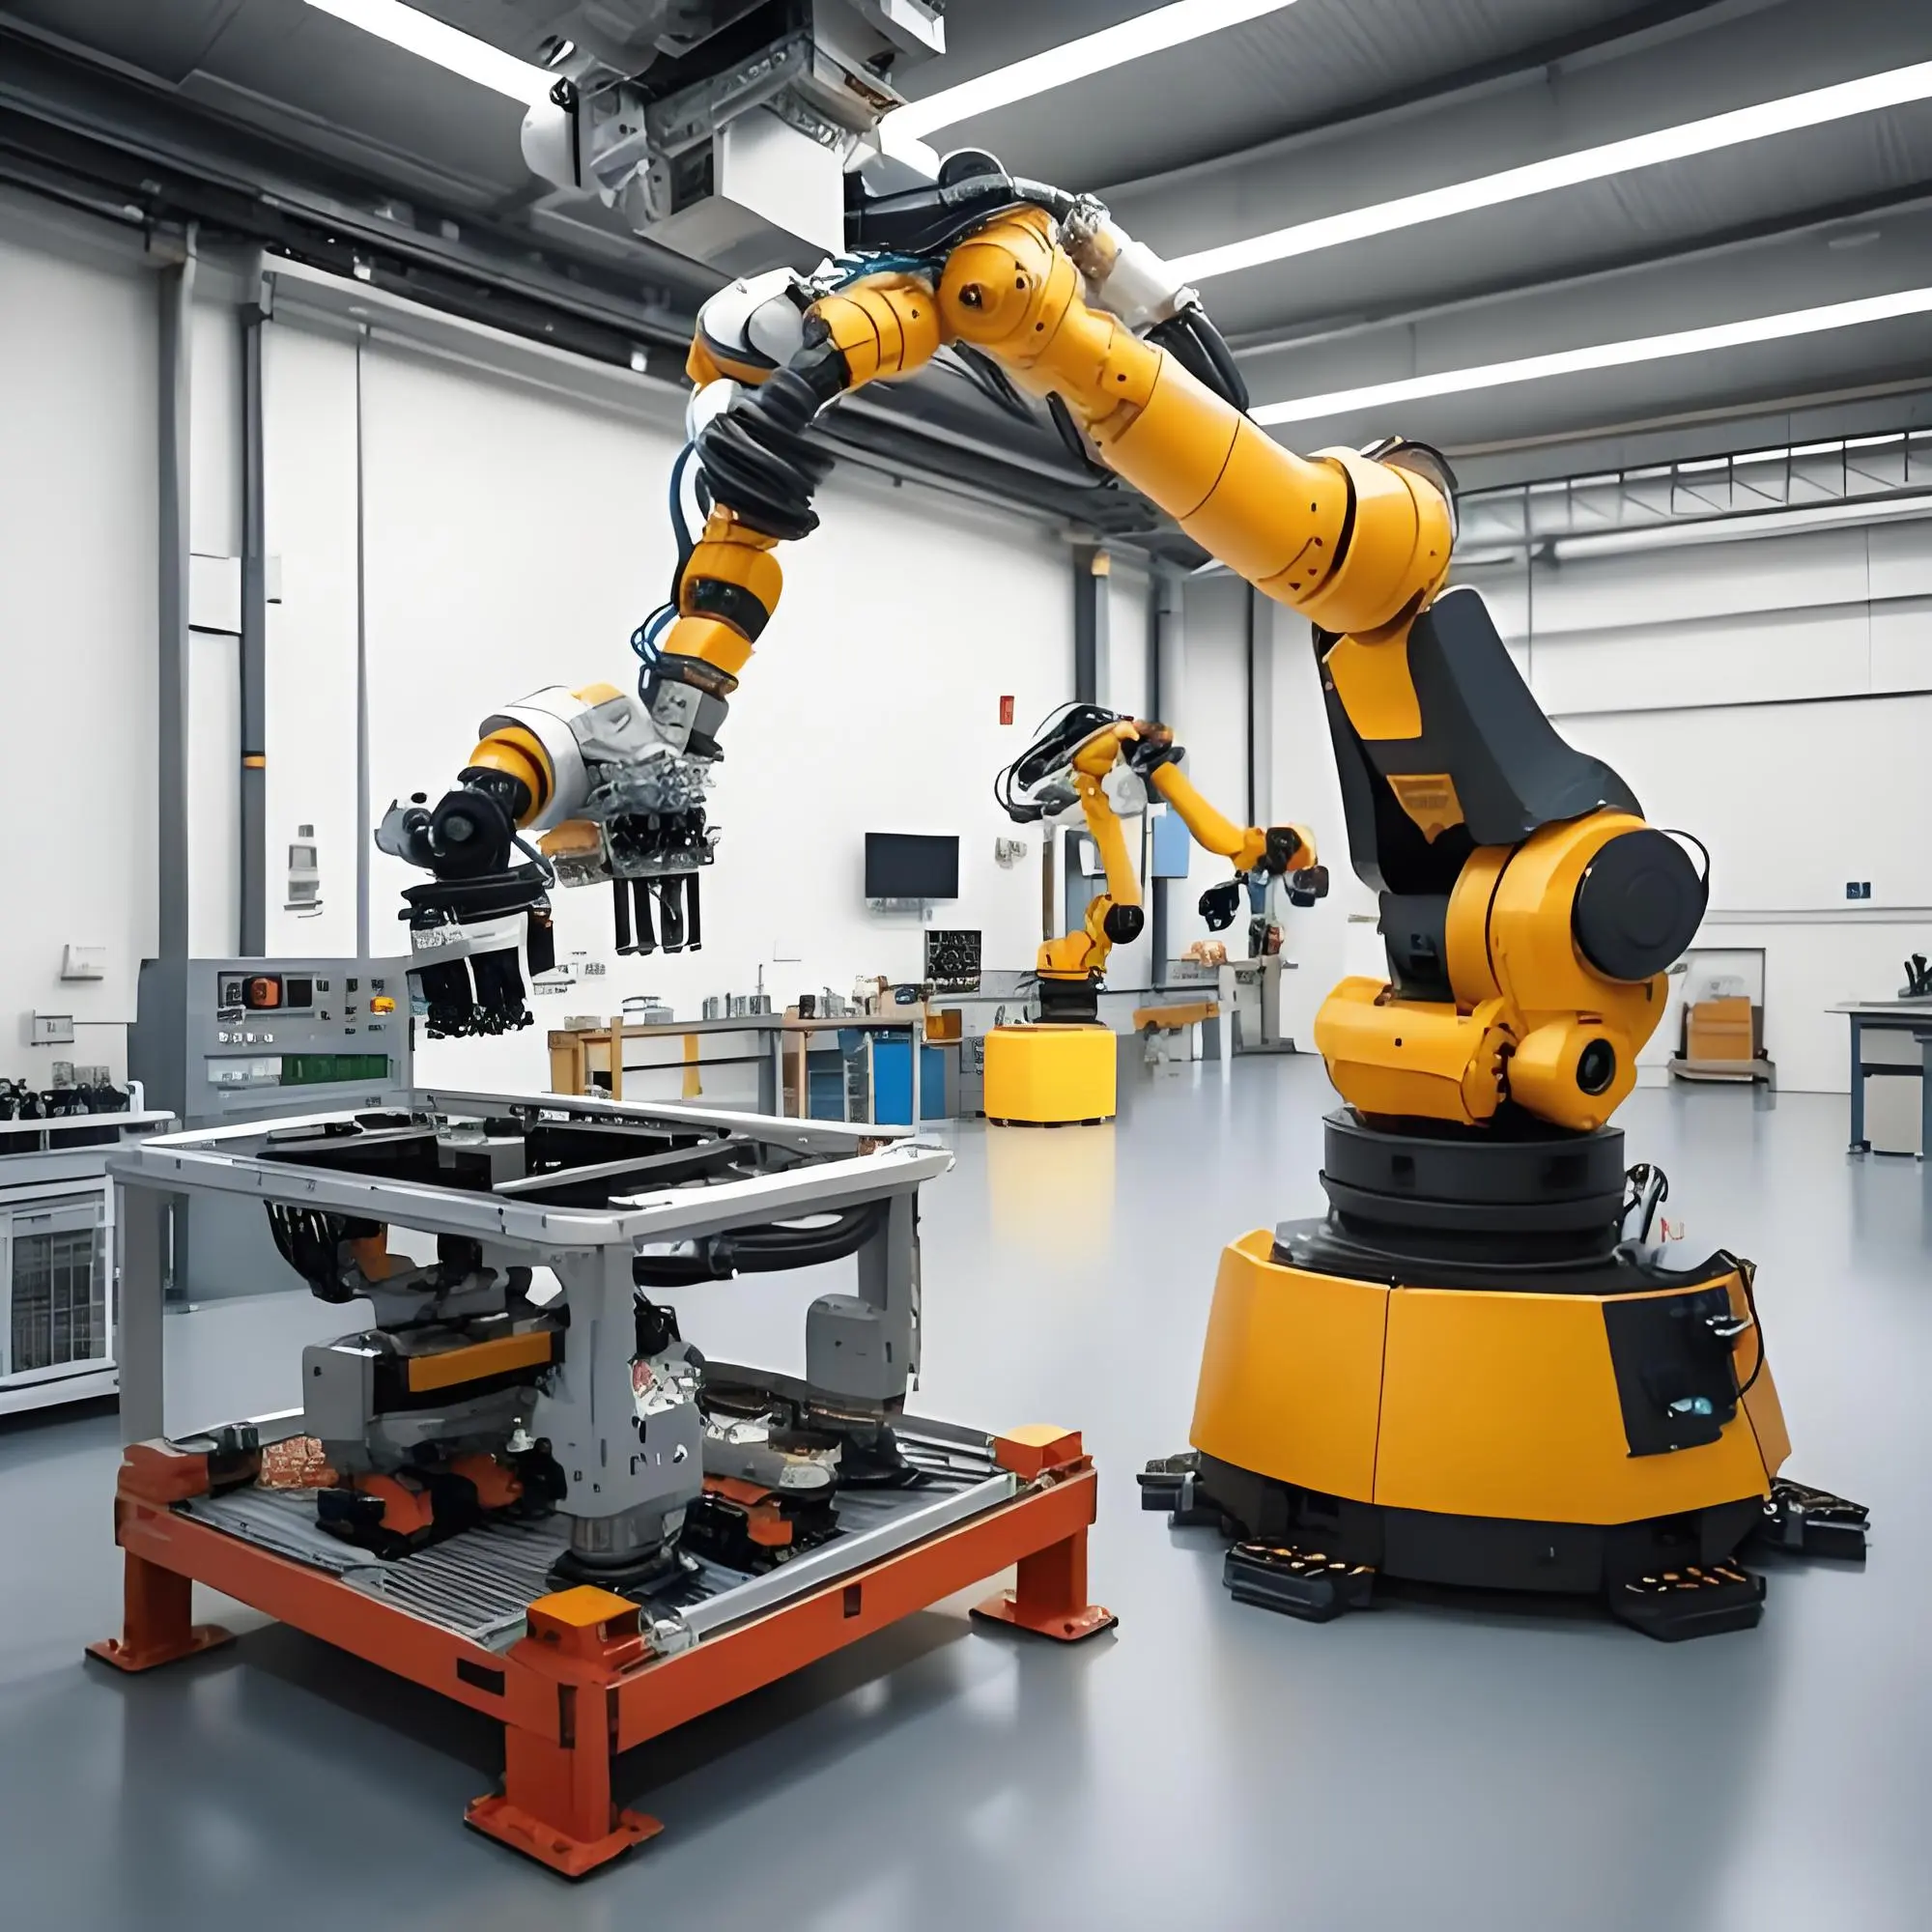
Yellow articulated industrial robot arms working around an assembly fixture
APPLICATION DETAILS

Application Description

This Content Is Managed in the Dashboard“Application Profiles”Maintain.

Harmonic reducers for compact robot joints

Industrial robot joints need controlled motion in a limited installation space. Harmonic, or strain-wave, reducers combine a compact transmission layout with low-backlash motion, making them a useful option when positioning performance, size and moving mass matter.

Recommended model: ANDANTEX CS25 Harmonic Reducer

ANDANTEX recommends evaluating the CS25 for suitable robot joint applications. Match the exact configuration to joint torque, speed, reduction ratio, stiffness and the motor interface. The selected reducer must support the full operating cycle, including acceleration and peak loads.

Typical application scenarios

  • Collaborative robots: compact joint assemblies where installation space and moving mass are important design constraints.
  • SCARA robots: rotary axes for repeatable assembly and pick-and-place motion, subject to cycle-time and load checks.
  • Six-axis articulated robots: suitable joints requiring compact reduction and controlled positioning. Each joint must be sized separately for its load and moment.

What determines positioning performance?

Gear backlash is only one part of joint performance. Torsional deflection, lost motion, bearing stiffness, encoder feedback and control tuning also affect the result. Confirm the CS25 specifications for the selected configuration rather than treating zero backlash as a guarantee of zero positioning error.

Request application matching

Send the robot type, joint location, payload, load offset, motion cycle, target speed and motor drawing. Our team can review the CS25 configuration and mounting requirements for your application.

MotorMatch by Application
Recommended ModelCS25 Harmonic Reducer
Key ParametersJoint torque, reduction ratio, torsional stiffness, positioning accuracy and mounting dimensions
Operating ConditionsRepeated positioning, direction changes and coordinated robot joint motion
WORKING CONDITIONS

What Matters Most When Selecting for This Application?

  • Calculate continuous, acceleration and emergency-stop torque for the specific joint.
  • Match the reduction ratio to the required joint speed and motor operating range.
  • Check torsional stiffness, lost motion and positioning accuracy under load.
  • Verify output bearing capacity, external moments and the mounting interface.
  • Confirm lubrication, duty cycle, operating temperature and service-life requirements.

Recommended Combination

CS25 Harmonic Reducer

Match the Actual Motor

View Product Resources →
SELECTION CHECKLIST

Information to Include in Your Selection Request

LoadWeight, Dimensions, Lever Arm, Center of Gravity
MotionTarget Speed, Angle, Travel, Acceleration & Deceleration Time
Cycle TimeTime per Cycle, Start/Stop Frequency, Daily Operating Hours
AccuracyPositioning Accuracy, Repeatability, Allowable Backlash
MotorPower, Model, Shaft Diameter, Shaft Length, Pilot Diameter, Hole Spacing
InstallationSpace, Orientation, Radial/Axial Force, Offset Load
← Back to All ApplicationsSubmit Selection Information →

ANDANTEX Product Assistant

Product guide · Beta
Guided catalogue search, not AI chat. Messages are not stored by this guide.